
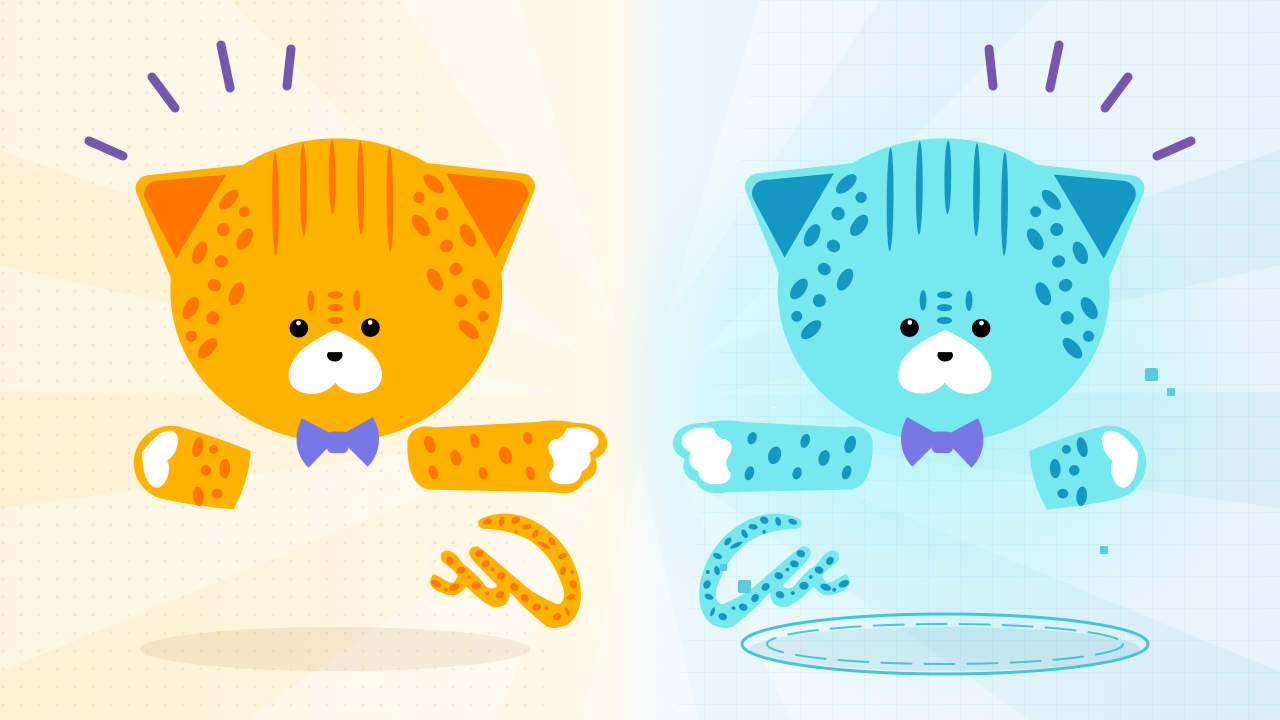
copper-rs 1.2: Live Telemetry Twins
Copper can now live-clone a running robot over unreliable, one-way links.
We stream only the minimal state required, use FEC to recover packet loss, then rely on Copper’s deterministic execution to reconstruct the robot’s full state remotely.
The result: a Twin Copper instance that can reproduce task state, messages, errors, structured logs and telemetry as if it were running onboard.
Also in v1.2:
• Up to 52% smaller Copper logs in our flight-controller example
• New cu-anynet anytime stereo depth reconstruction
• More ROS 2 compatibility improvements
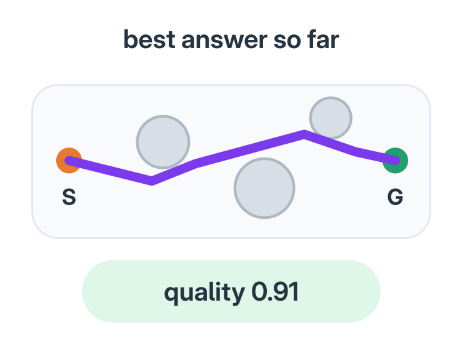
Anytime Algorithms Support landed in v1.1.0
An empty street and a concert crowd demand very different amounts of computation. Copper v1.1 brings anytime algorithms into the scheduler, letting robotics tasks publish a safe initial result, improve it through bounded refinement steps, and stop when quality, time, or freshness limits are reached. The result is smarter use of compute across perception, planning, and ML, while preserving deterministic replay.
Double v1.1 and v1.0.2 releases.
Copper v1.1 is here 🎉 … alongside v1.0.2 compatibility fixes. This release brings anytime algorithms into the scheduler, more robot configuration to compile time, and better tools for turning generated execution plans into recorded timing you can actually inspect.